Medical Projects
Multi-Clip Ligation Tool
Designed a secondary tool allowing for multiple Hem-o-lok clips to be placed without needing to remove and reinsert the clip applier for each individual clip during da Vinci robotic surgeries. (Spring 2026)
Patent Process in Progress

Endoscope Robotic Tools with Increased Mobility
Continuum robotics research completed in the Bertram Lab at Duke University. My research focused on creating prototype robots with greater maneuverability and a larger work space to replace traditional forceps and snares. (Spring 2026)

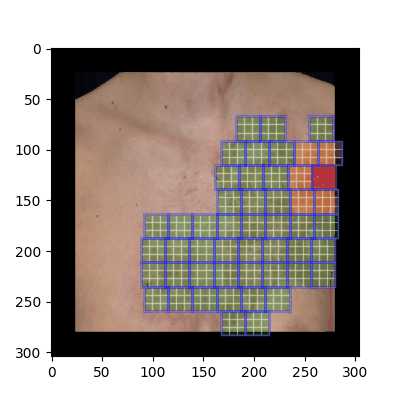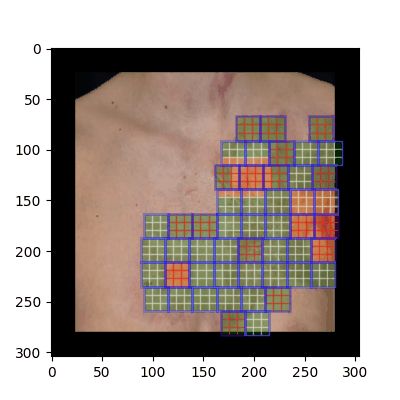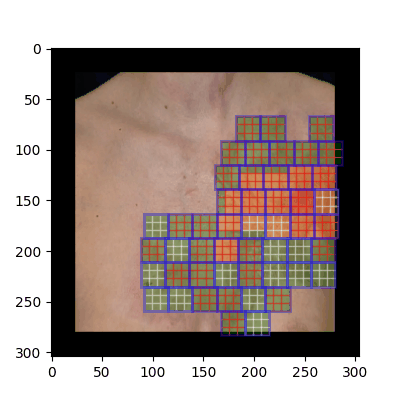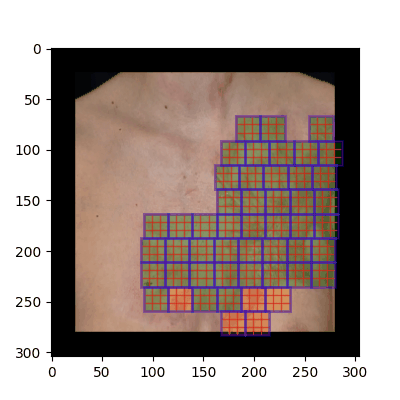
Designed and programmed methods to segment scars from the surrounding healthy tissue and then utilized machine/robot learning to path plan for a hypothetical laser surgical procedure. (Fall 2025)
This prototype is a tendon-actuated concentric tube endonasal robot. In this design, two tendon-actuated robots are concentric to each other, resulting in two robots each capable of bending independently. (Spring 2025)
